 CN
 sales@hisciences.com


The required output torque depends on the joint load, mechanical structure, movement speed, and acceleration. Engineers should consider the torque generated by gravity, external forces, friction, and rotational inertia during operation.
For a preliminary calculation, the torque generated by a force can be estimated using the force multiplied by its perpendicular distance from the joint axis. Additional torque is required to accelerate or decelerate moving components.
Both continuous and peak operating conditions should be evaluated. The selected module must provide sufficient rated torque for normal operation and adequate peak torque for short-term dynamic loads. The required safety margin depends on the application, duty cycle, and operating conditions. Consult the manufacturer before finalizing the model.
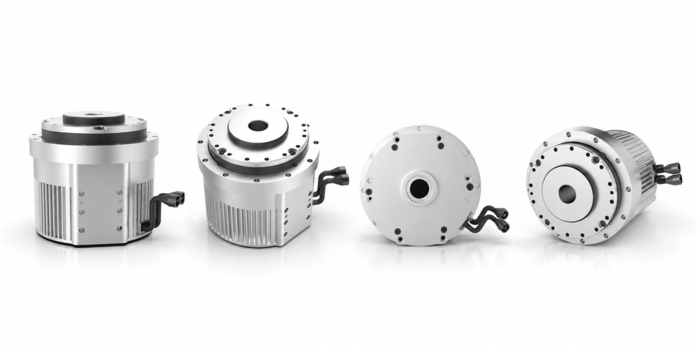
Related Product: HISCIENCE Joint Modules
 Back to list